Simulation training
Chubu
Bipedal robot
Chubu is the bipedal robot I’m building. It learns to lift and place its feet from reference motions in MuJoCo, then uses reinforcement learning to improve walking balance.
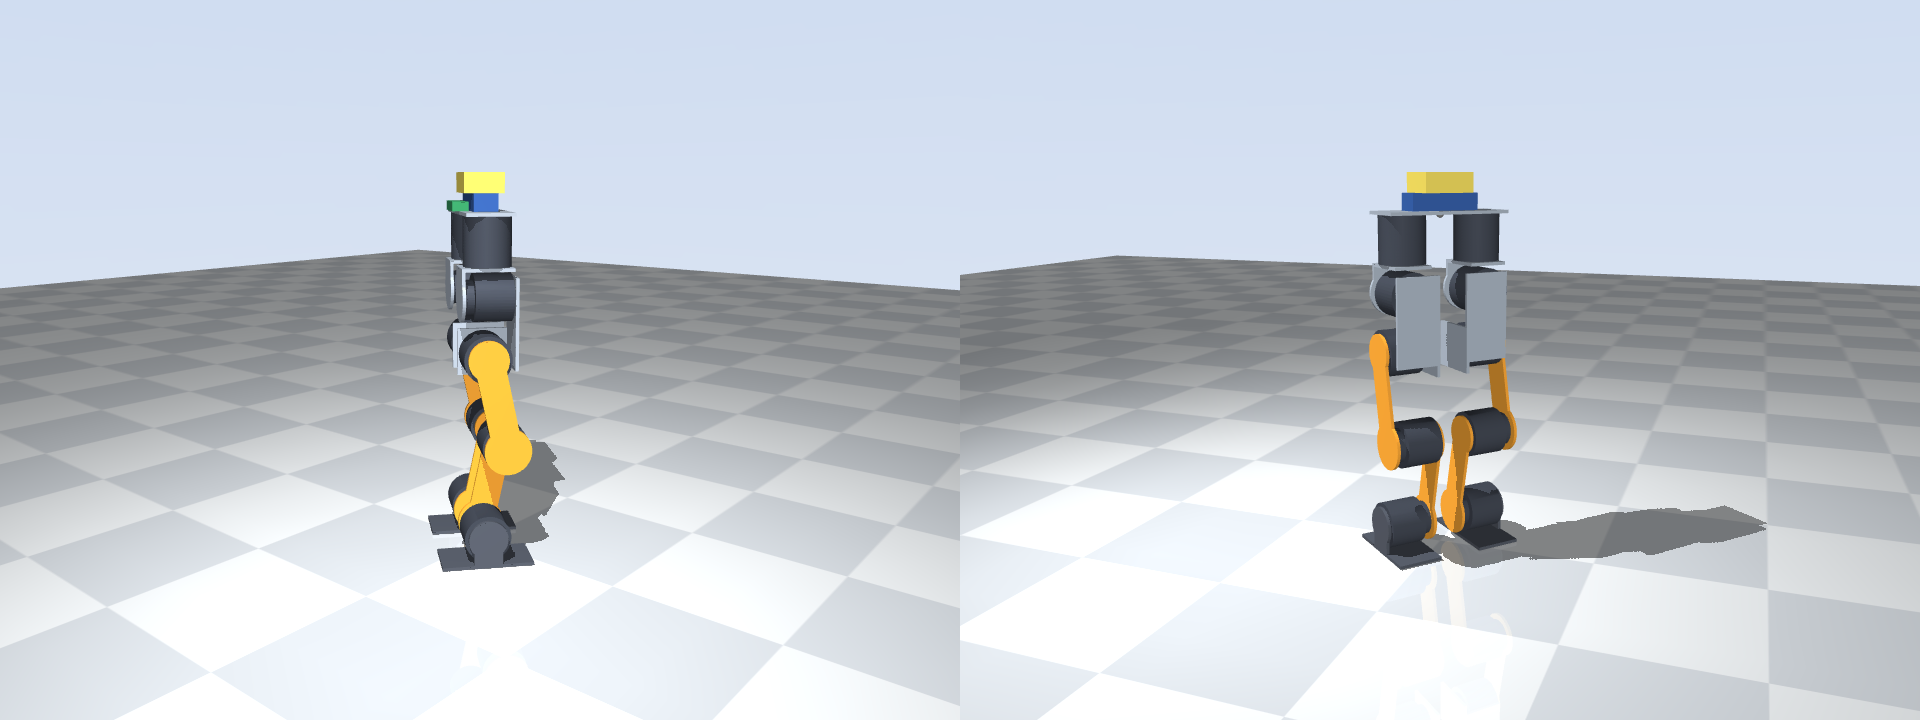
- Robot joints
- 10
- Policy update interval
- 20 ms
- Simulator
- MuJoCo
Mechanics and motor driver
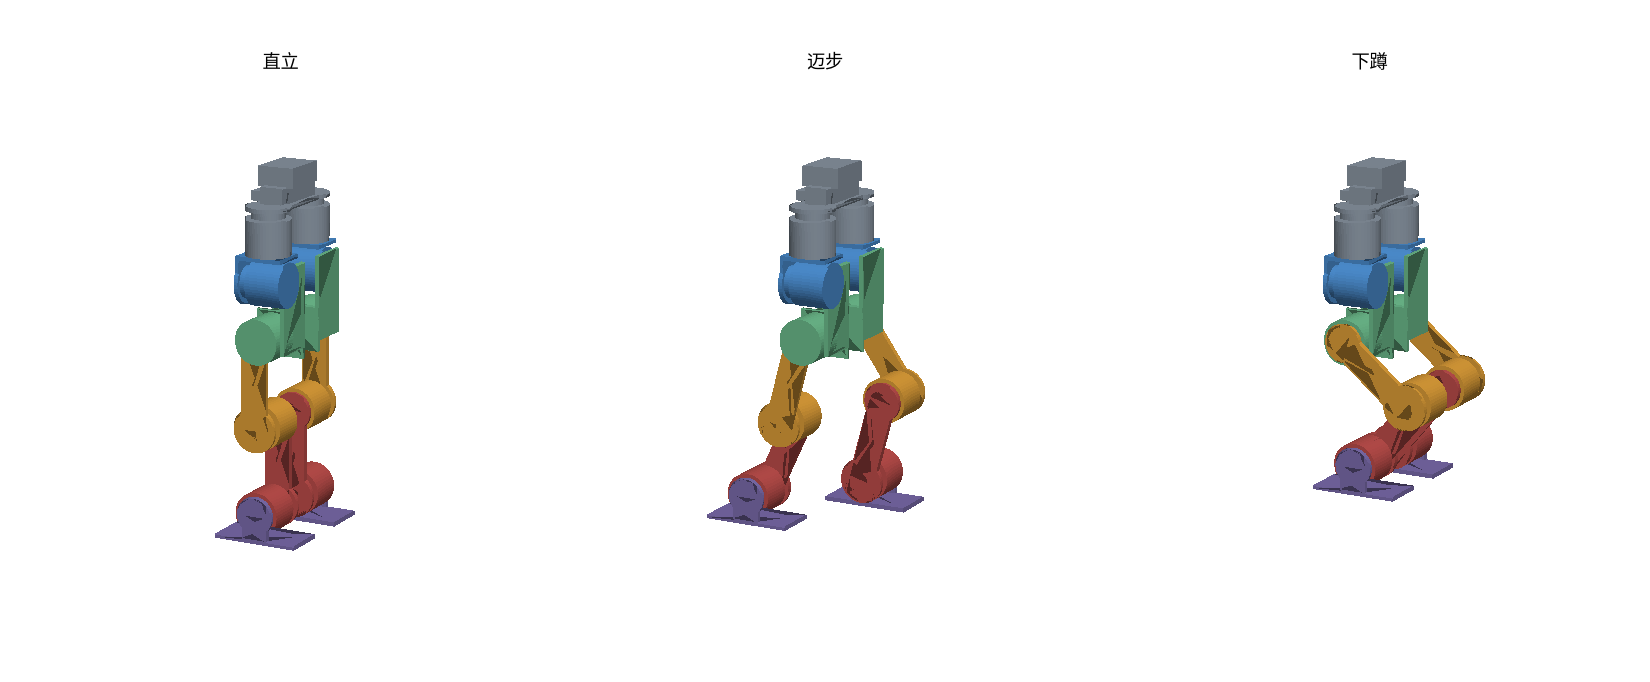
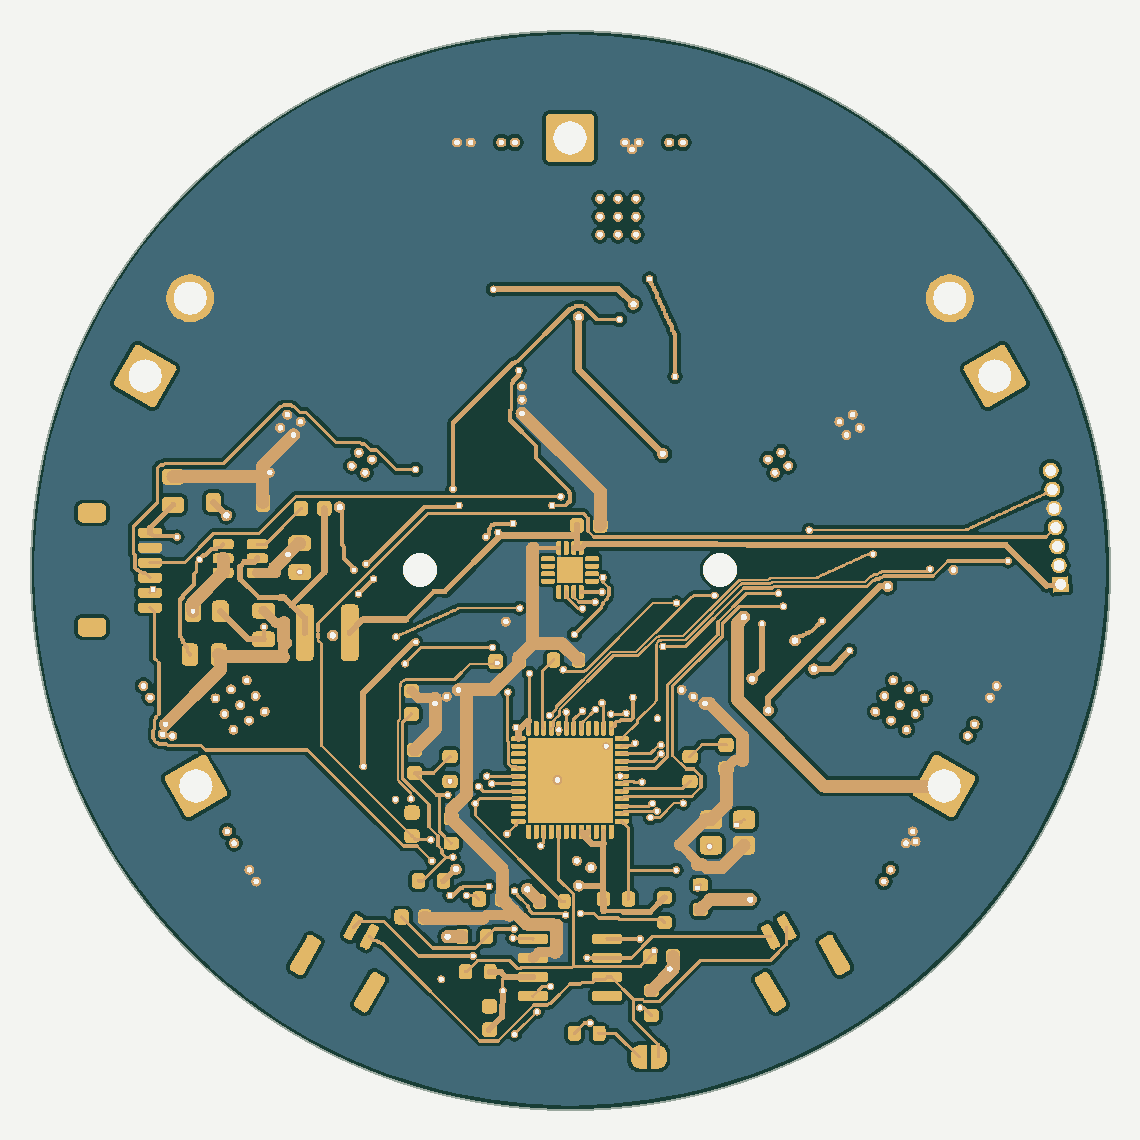
Gait training
Reference gait
A gait clock and reference trajectories guide the leg swing, foot lift, and touchdown.
Reinforcement learning
PPO optimizes the policy. Every 20 ms the policy outputs target angle offsets for all 10 joints. Training accounts for balance, foot slip, and touchdown impact.
Current progress
The mechanical layout, joint driver schematic and PCB layout, and bill of materials are complete. Each leg has three hip joints, a knee joint, and an ankle joint.
The current work is simulation training and motion checks. Physical assembly and hardware testing come next.